
Teaching
I have taught and assisted in courses on control, estimation, and mechanics at Caltech, ETH Zurich, and EPFL. From January 2027 I will be teaching in the Department of Engineering at Cambridge.
Courses
-
Optimal Control and Estimation (CDS 112 / Ae 103b)
Caltech, Winter 2023. Professor: Richard M. Murray. -
Aerospace Control Systems (Ae 103a)
Caltech, Fall 2023. Professor: Amir Rahmani (JPL). -
Control Systems II
ETH Zürich, Spring 2020. Professor: Roy Smith. -
Thermodynamics
EPFL, Spring 2017. Professor: Véronique Michaud. -
Analytical Mechanics
EPFL, Spring 2016. Professor: Philippe Müllhaupt.
Interactive demos
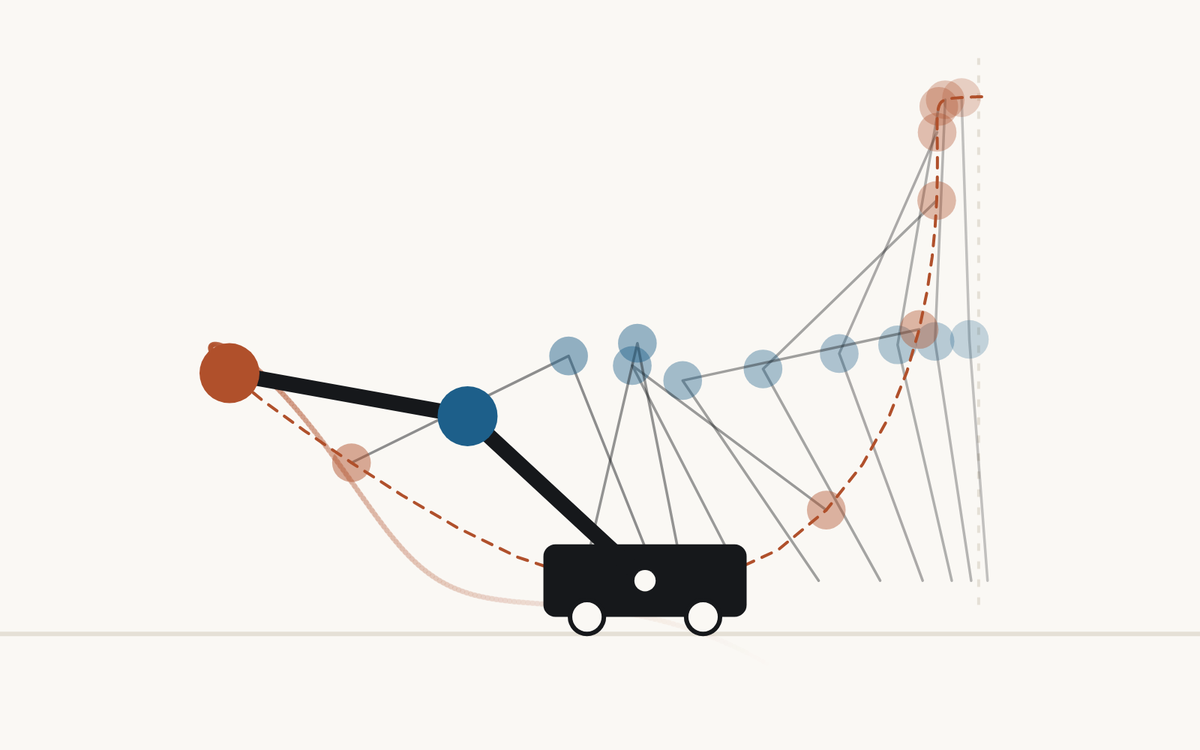
Optimal Control & Estimation
Model predictive control
A nonlinear MPC swings up and balances a double pendulum on a cart. Push it and watch it re-plan. With the receding horizon formulation, its transcription by multiple shooting, and the CasADi code behind it.
Try the demo →
If you are looking for a project to work on with me, see Openings.