
Research / Featured research
Learning-Based Control
We combine machine learning with physics-based control so robots can move with agility and adapt to new conditions, while their behaviour stays interpretable.
In the media: Caltech News
Quadrotor morpho-transition: learning vs model-based control strategies
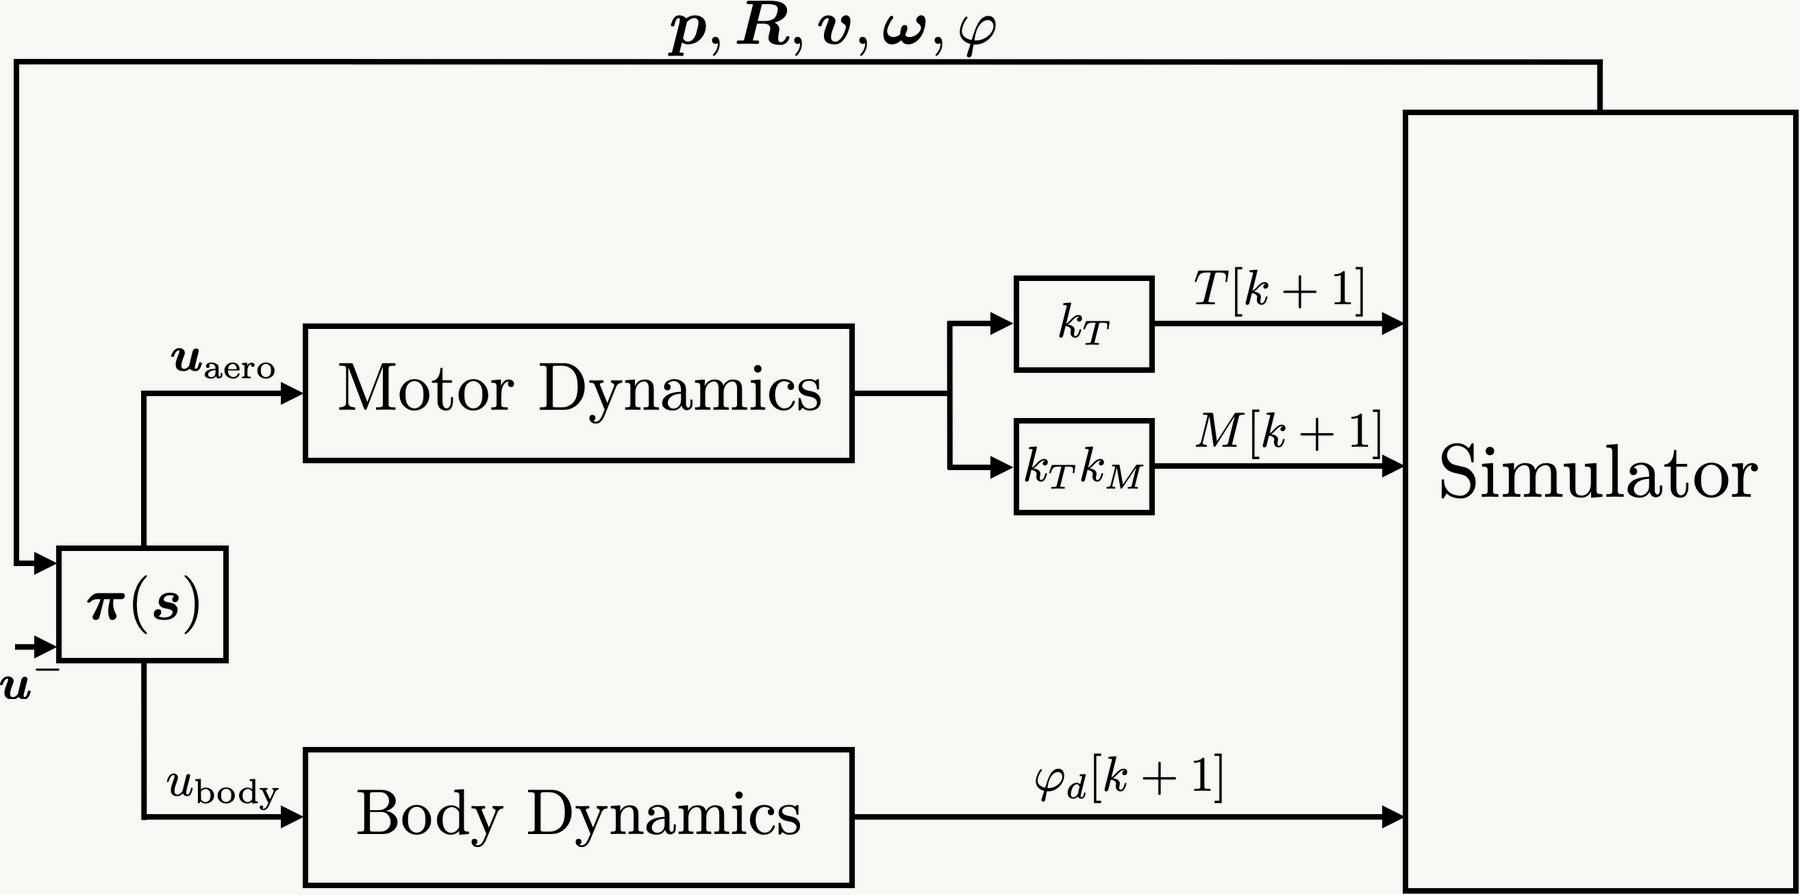
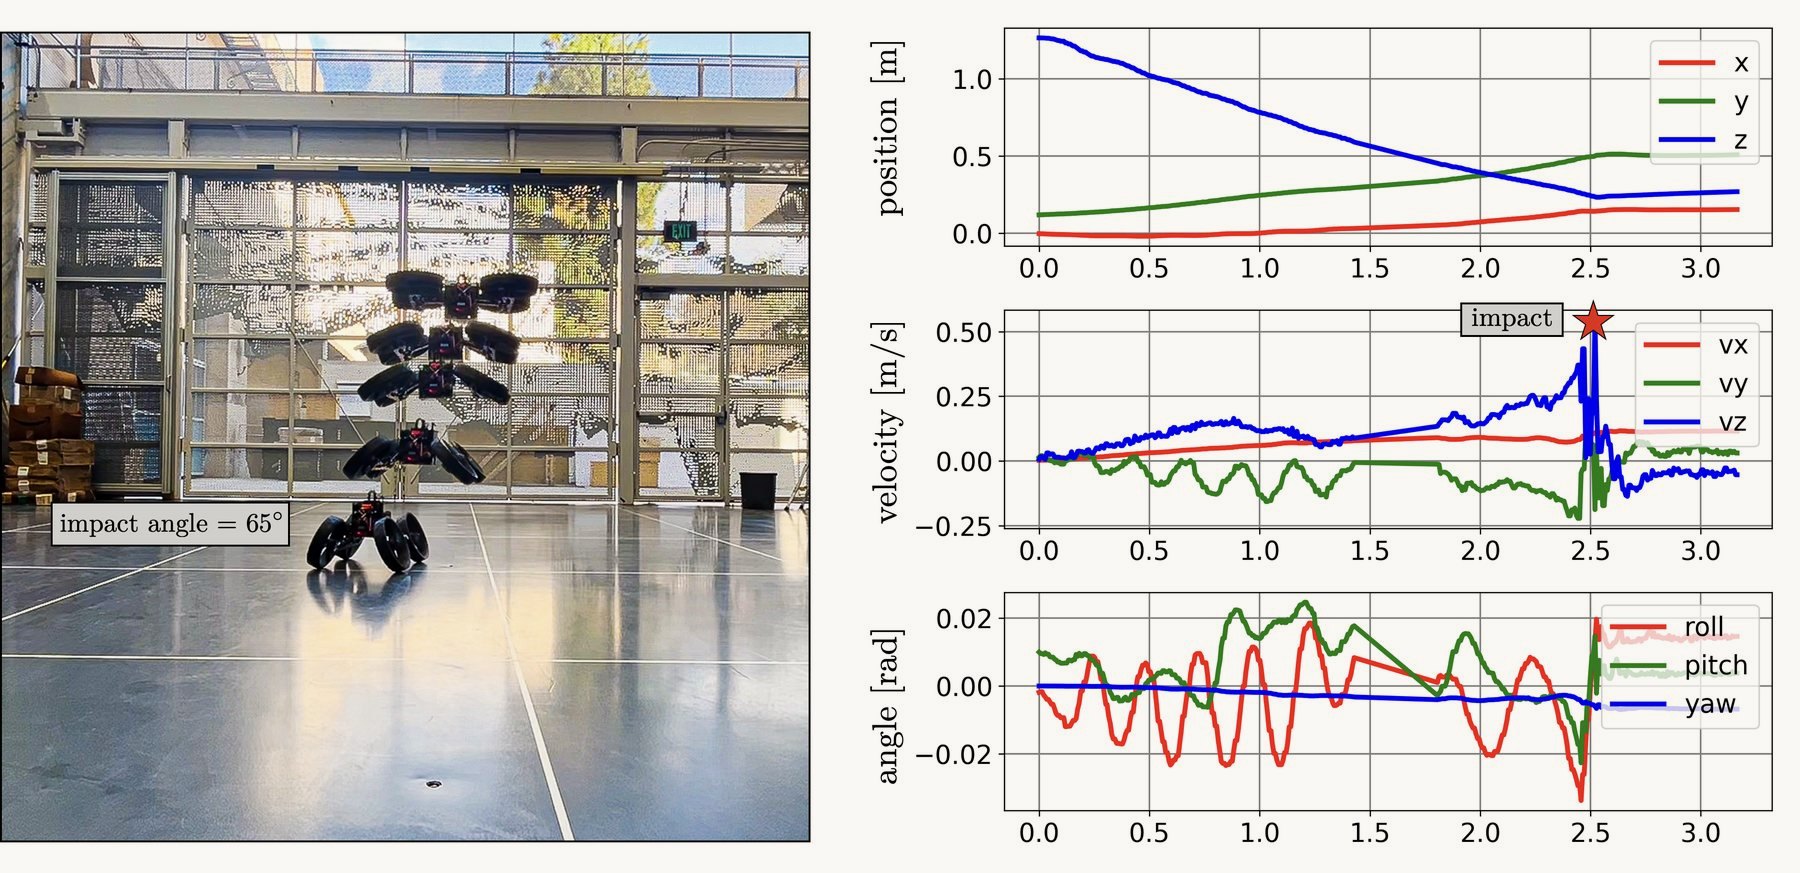
Landing by transformation drives a quadrotor to the edge of actuator saturation. On hardware, an end-to-end reinforcement learning policy lands with more agility, but only once motor dynamics and sensing delays are part of its training world. Model-predictive control transfers out of the box, yet recovers less gracefully when actuators fail unexpectedly.
Learning efficient navigation in vortical flow fields
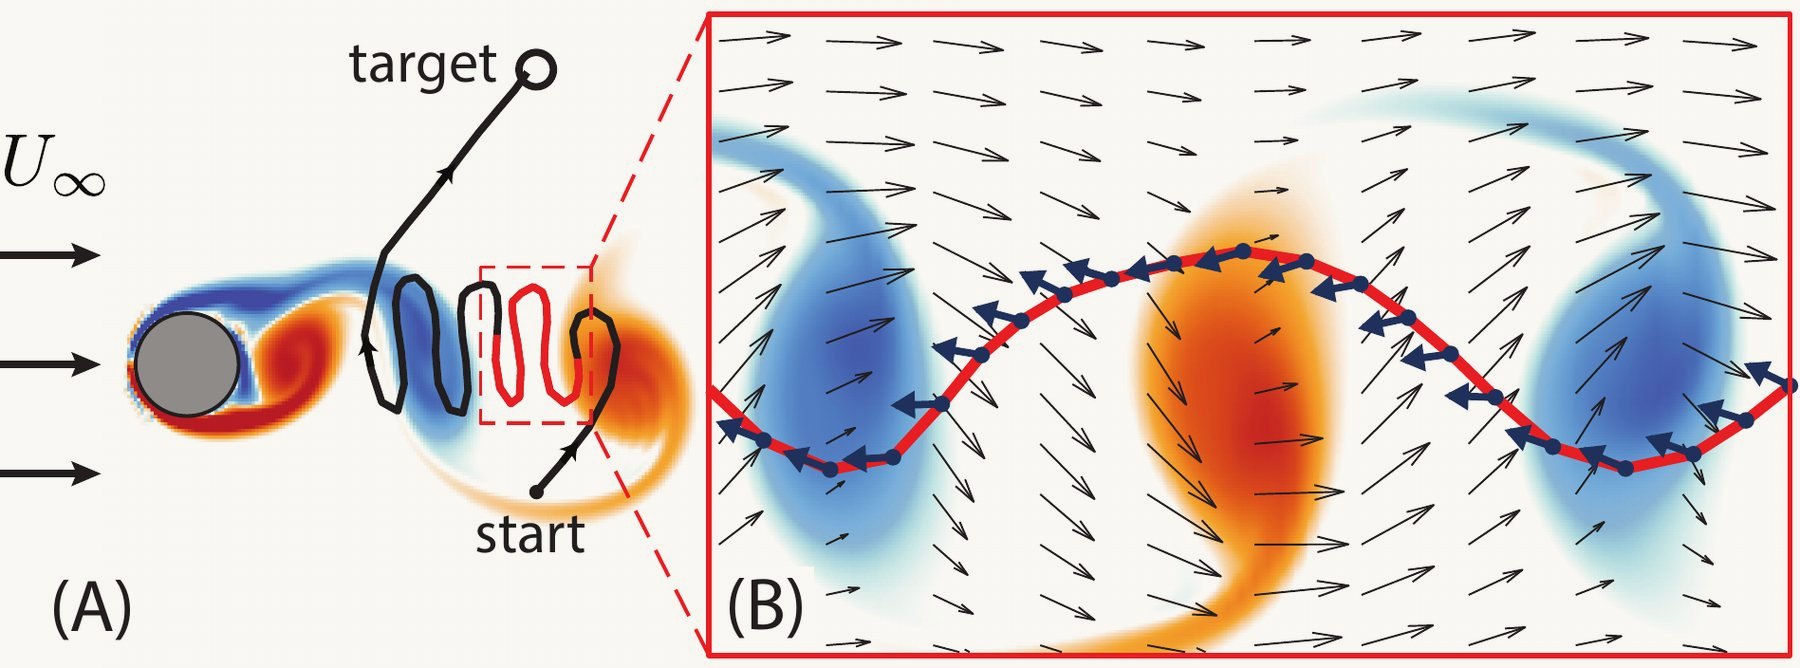
Reaching a target through unsteady currents with only local information. Reinforcement learning finds navigation policies for a fixed-speed swimmer in a cylinder wake that use the flow rather than fight it. What the swimmer senses matters: sensing velocity outperformed bio-inspired vorticity sensing, reaching the target nearly every time and approaching the travel time of optimal trajectories.
More research Ground-Aerial Morphing Robotics · Fluid-Body Interaction and Flow Control · Vision-Based Navigation and Manipulation